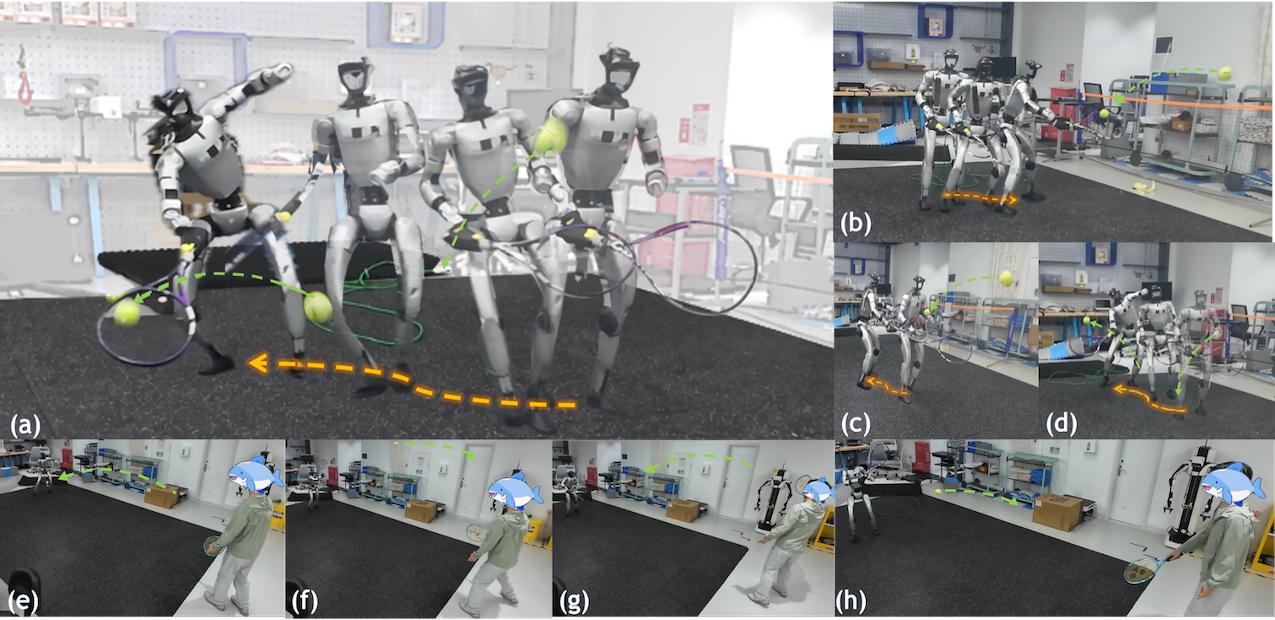
ATHLETE: Learning Reactive Humanoid Tennis via Trajectory-Guided Motion Matching
ICRA 2027 · Under review
Learning reactive humanoid tennis from reusable locomotion data and video demonstrations through trajectory-guided motion matching.
I am an M.Phil. student in the Artificial Intelligence Thrust, Information Hub at HKUST (Guangzhou), supported by a full scholarship (2026–2028). I work with Prof. Junwei Liang at the Precognition Lab.
My research interests lie in robot learning, humanoid whole-body control, and motion planning. I am interested in building robots that learn useful skills and move effectively in the physical world.
Previously, I worked at the FAST Lab, Zhejiang University, with Dr. Yanjun Cao and Prof. Chao Xu. I received my B.Eng. in Mechanical and Electronic Engineering from Nanjing Institute of Technology.

From reconfigurable mobile robots to humanoid tennis, my work connects robot design, motion planning, and learning-based control.
ICRA 2027 · Under review
Learning reactive humanoid tennis from reusable locomotion data and video demonstrations through trajectory-guided motion matching.
ICRA, 2025
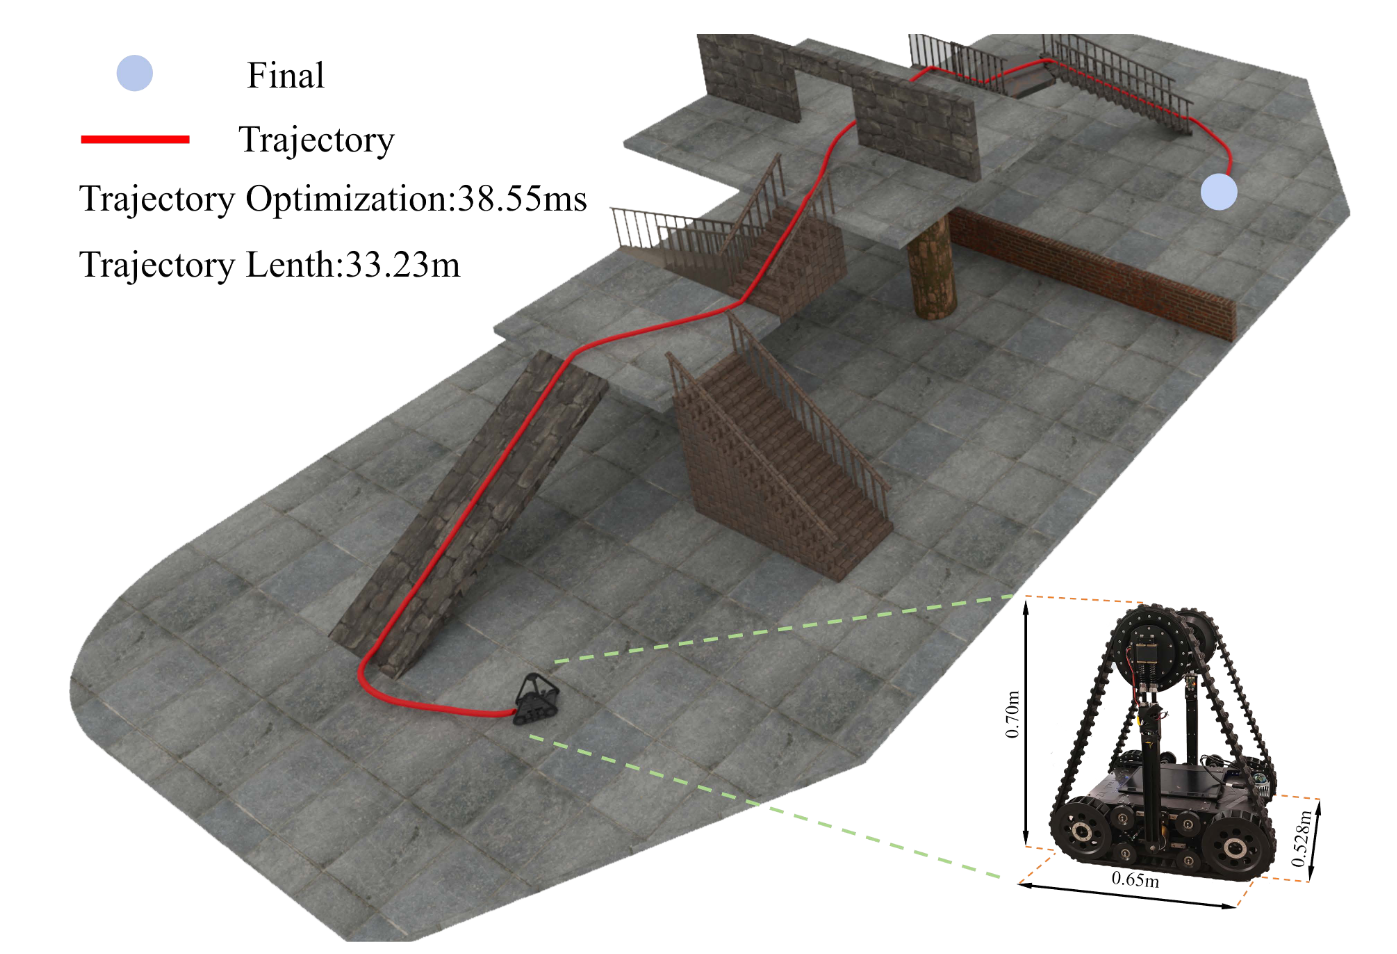
Efficient ground-robot navigation through multi-level architecture using traversable planes extracted from 3D point clouds.
IROS, 2024 · Oral
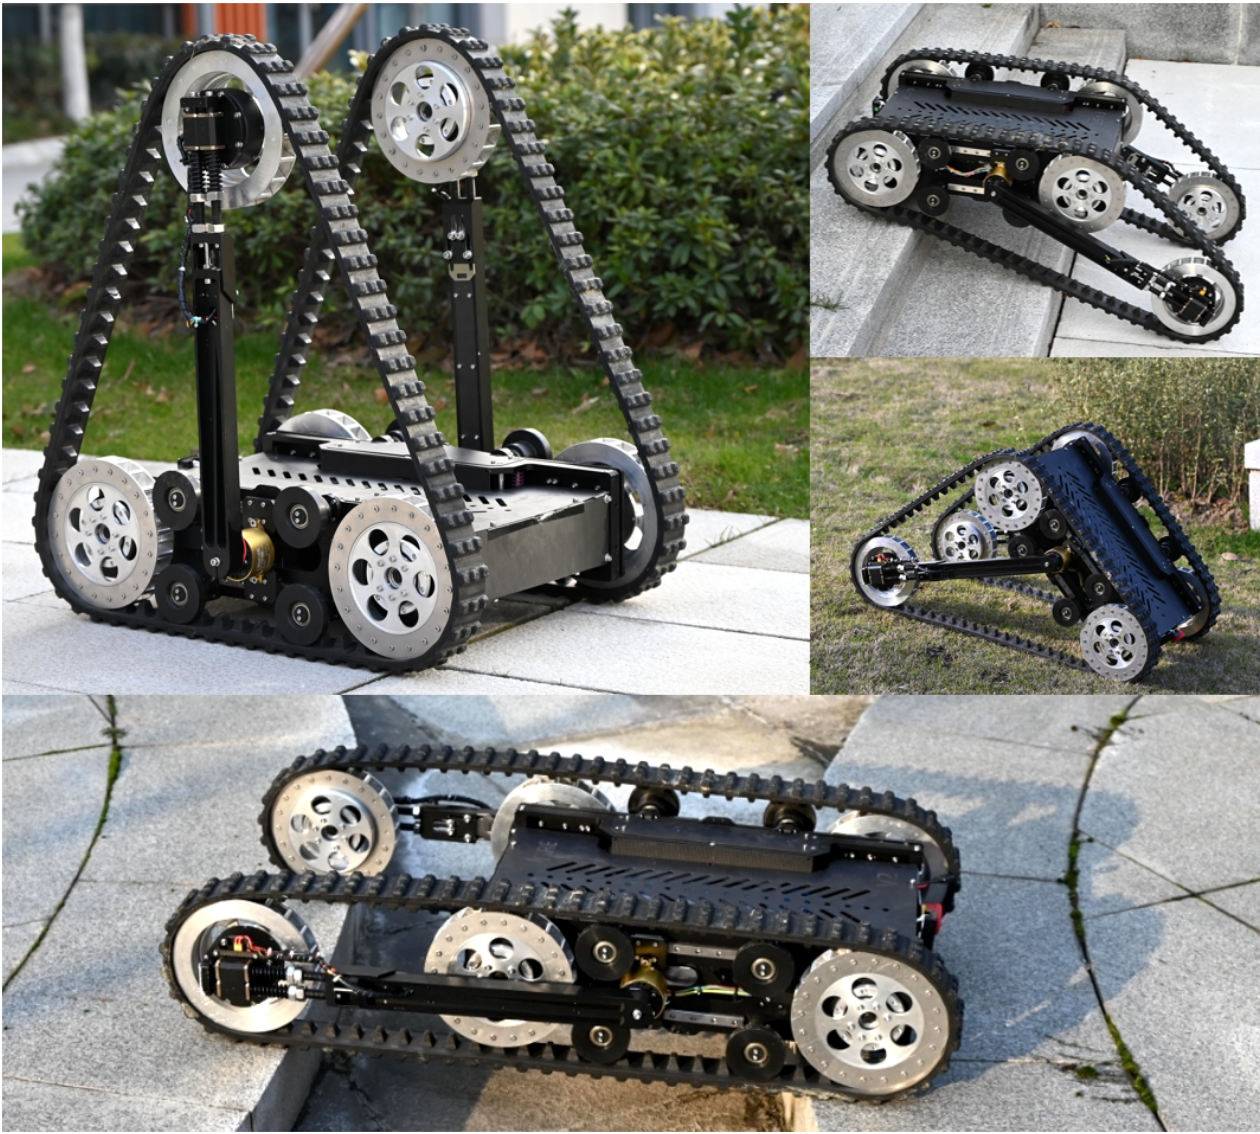
Geometry-changing tracks enable a reconfigurable robot to adapt to challenging terrain and traverse obstacles.
† Equal contribution.
I enjoy building things, from robot hardware to small everyday devices.
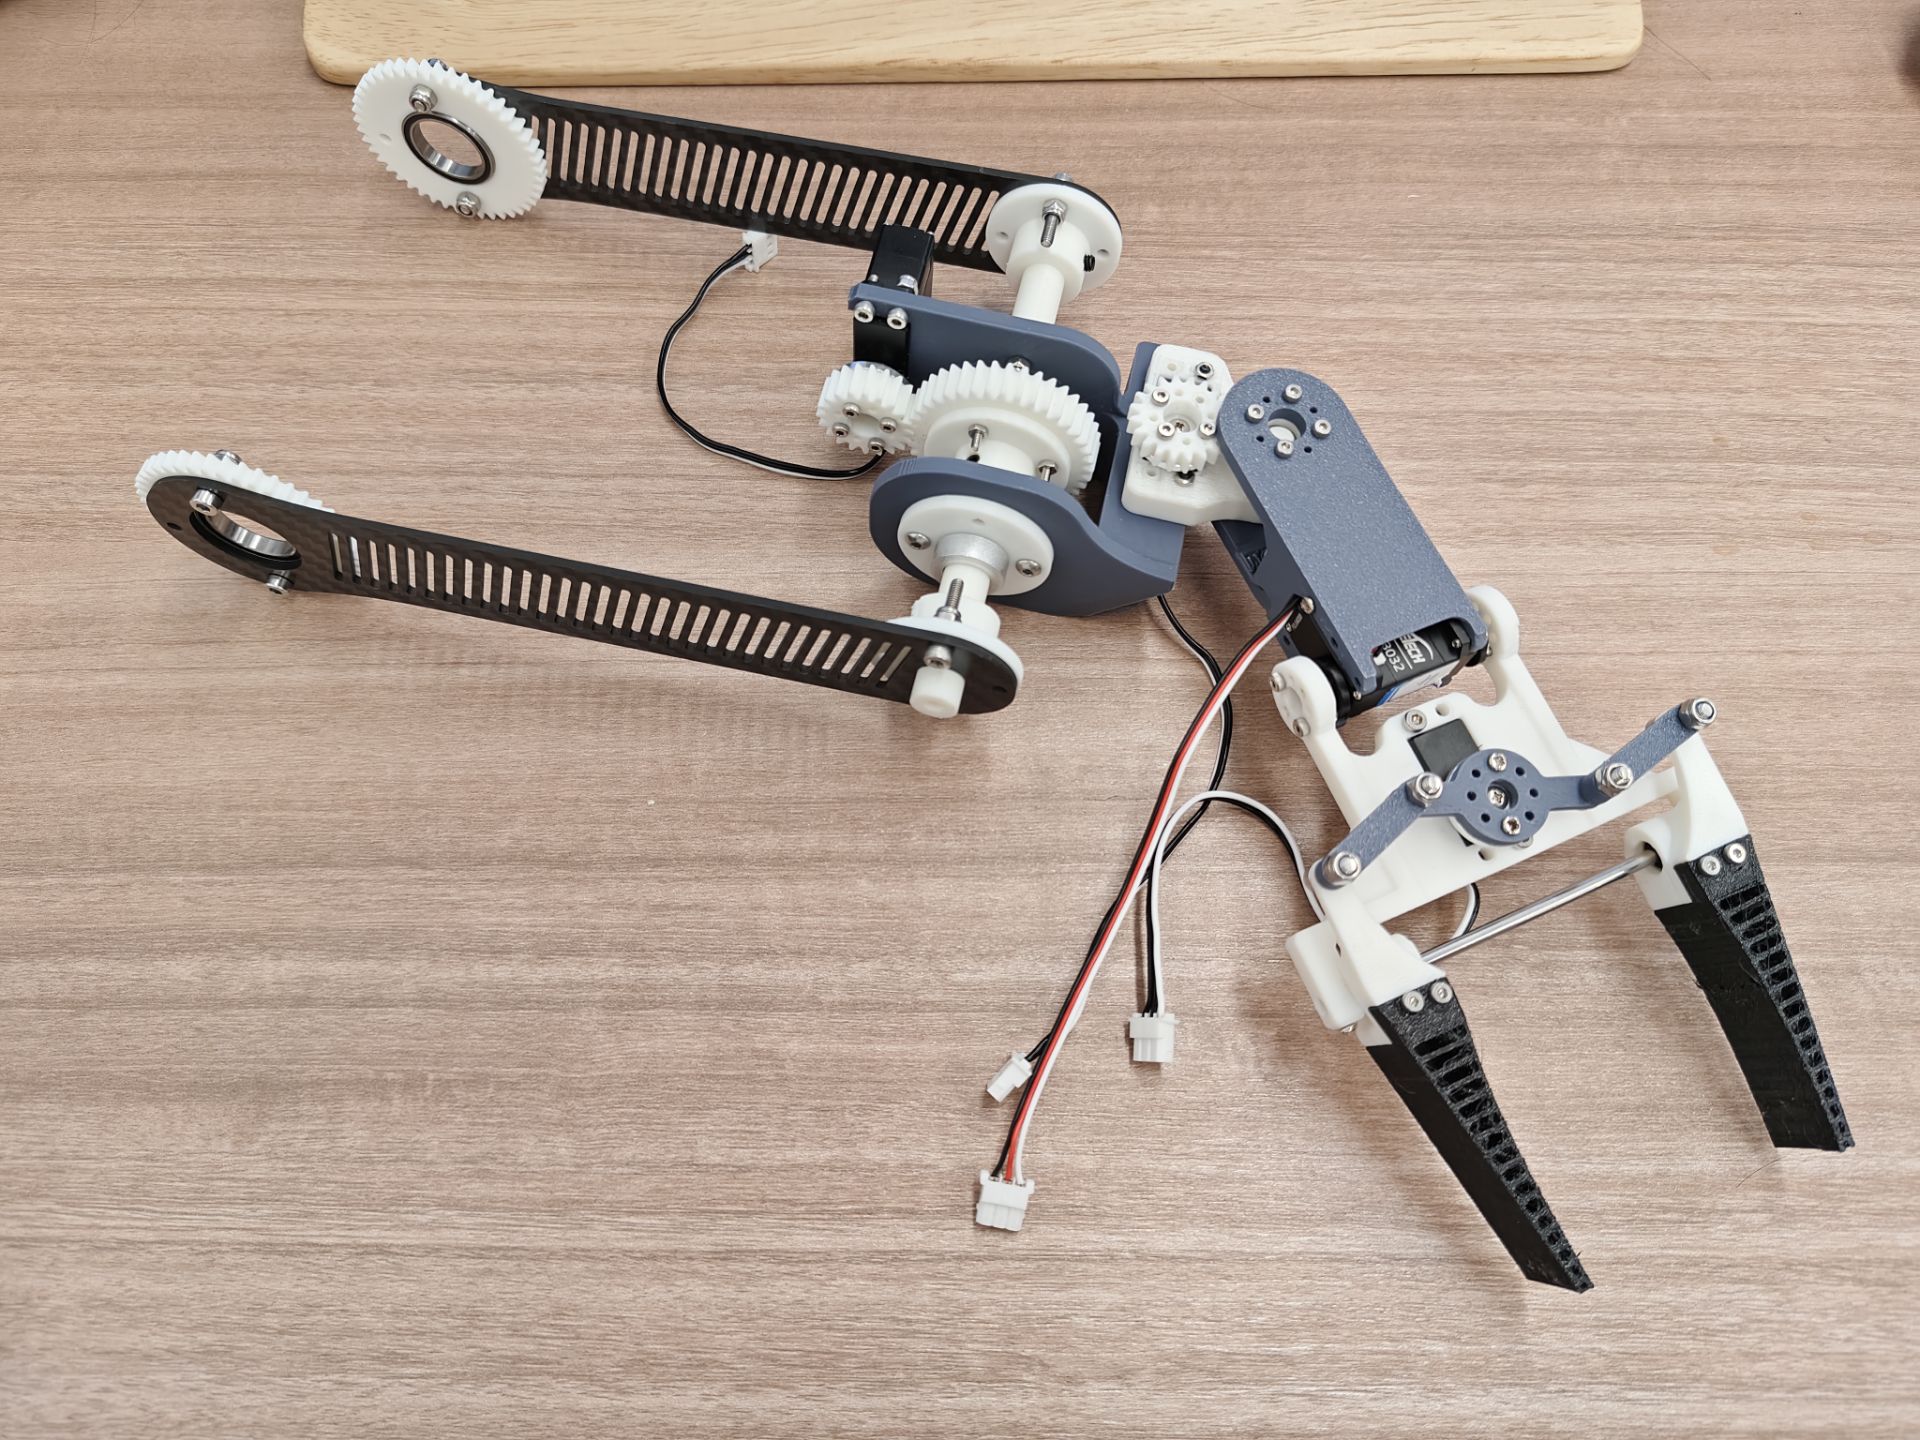
A 5-DOF arm with a flexible gripper, reproduced from the design shown in CHAT-PM.
reference paper ↗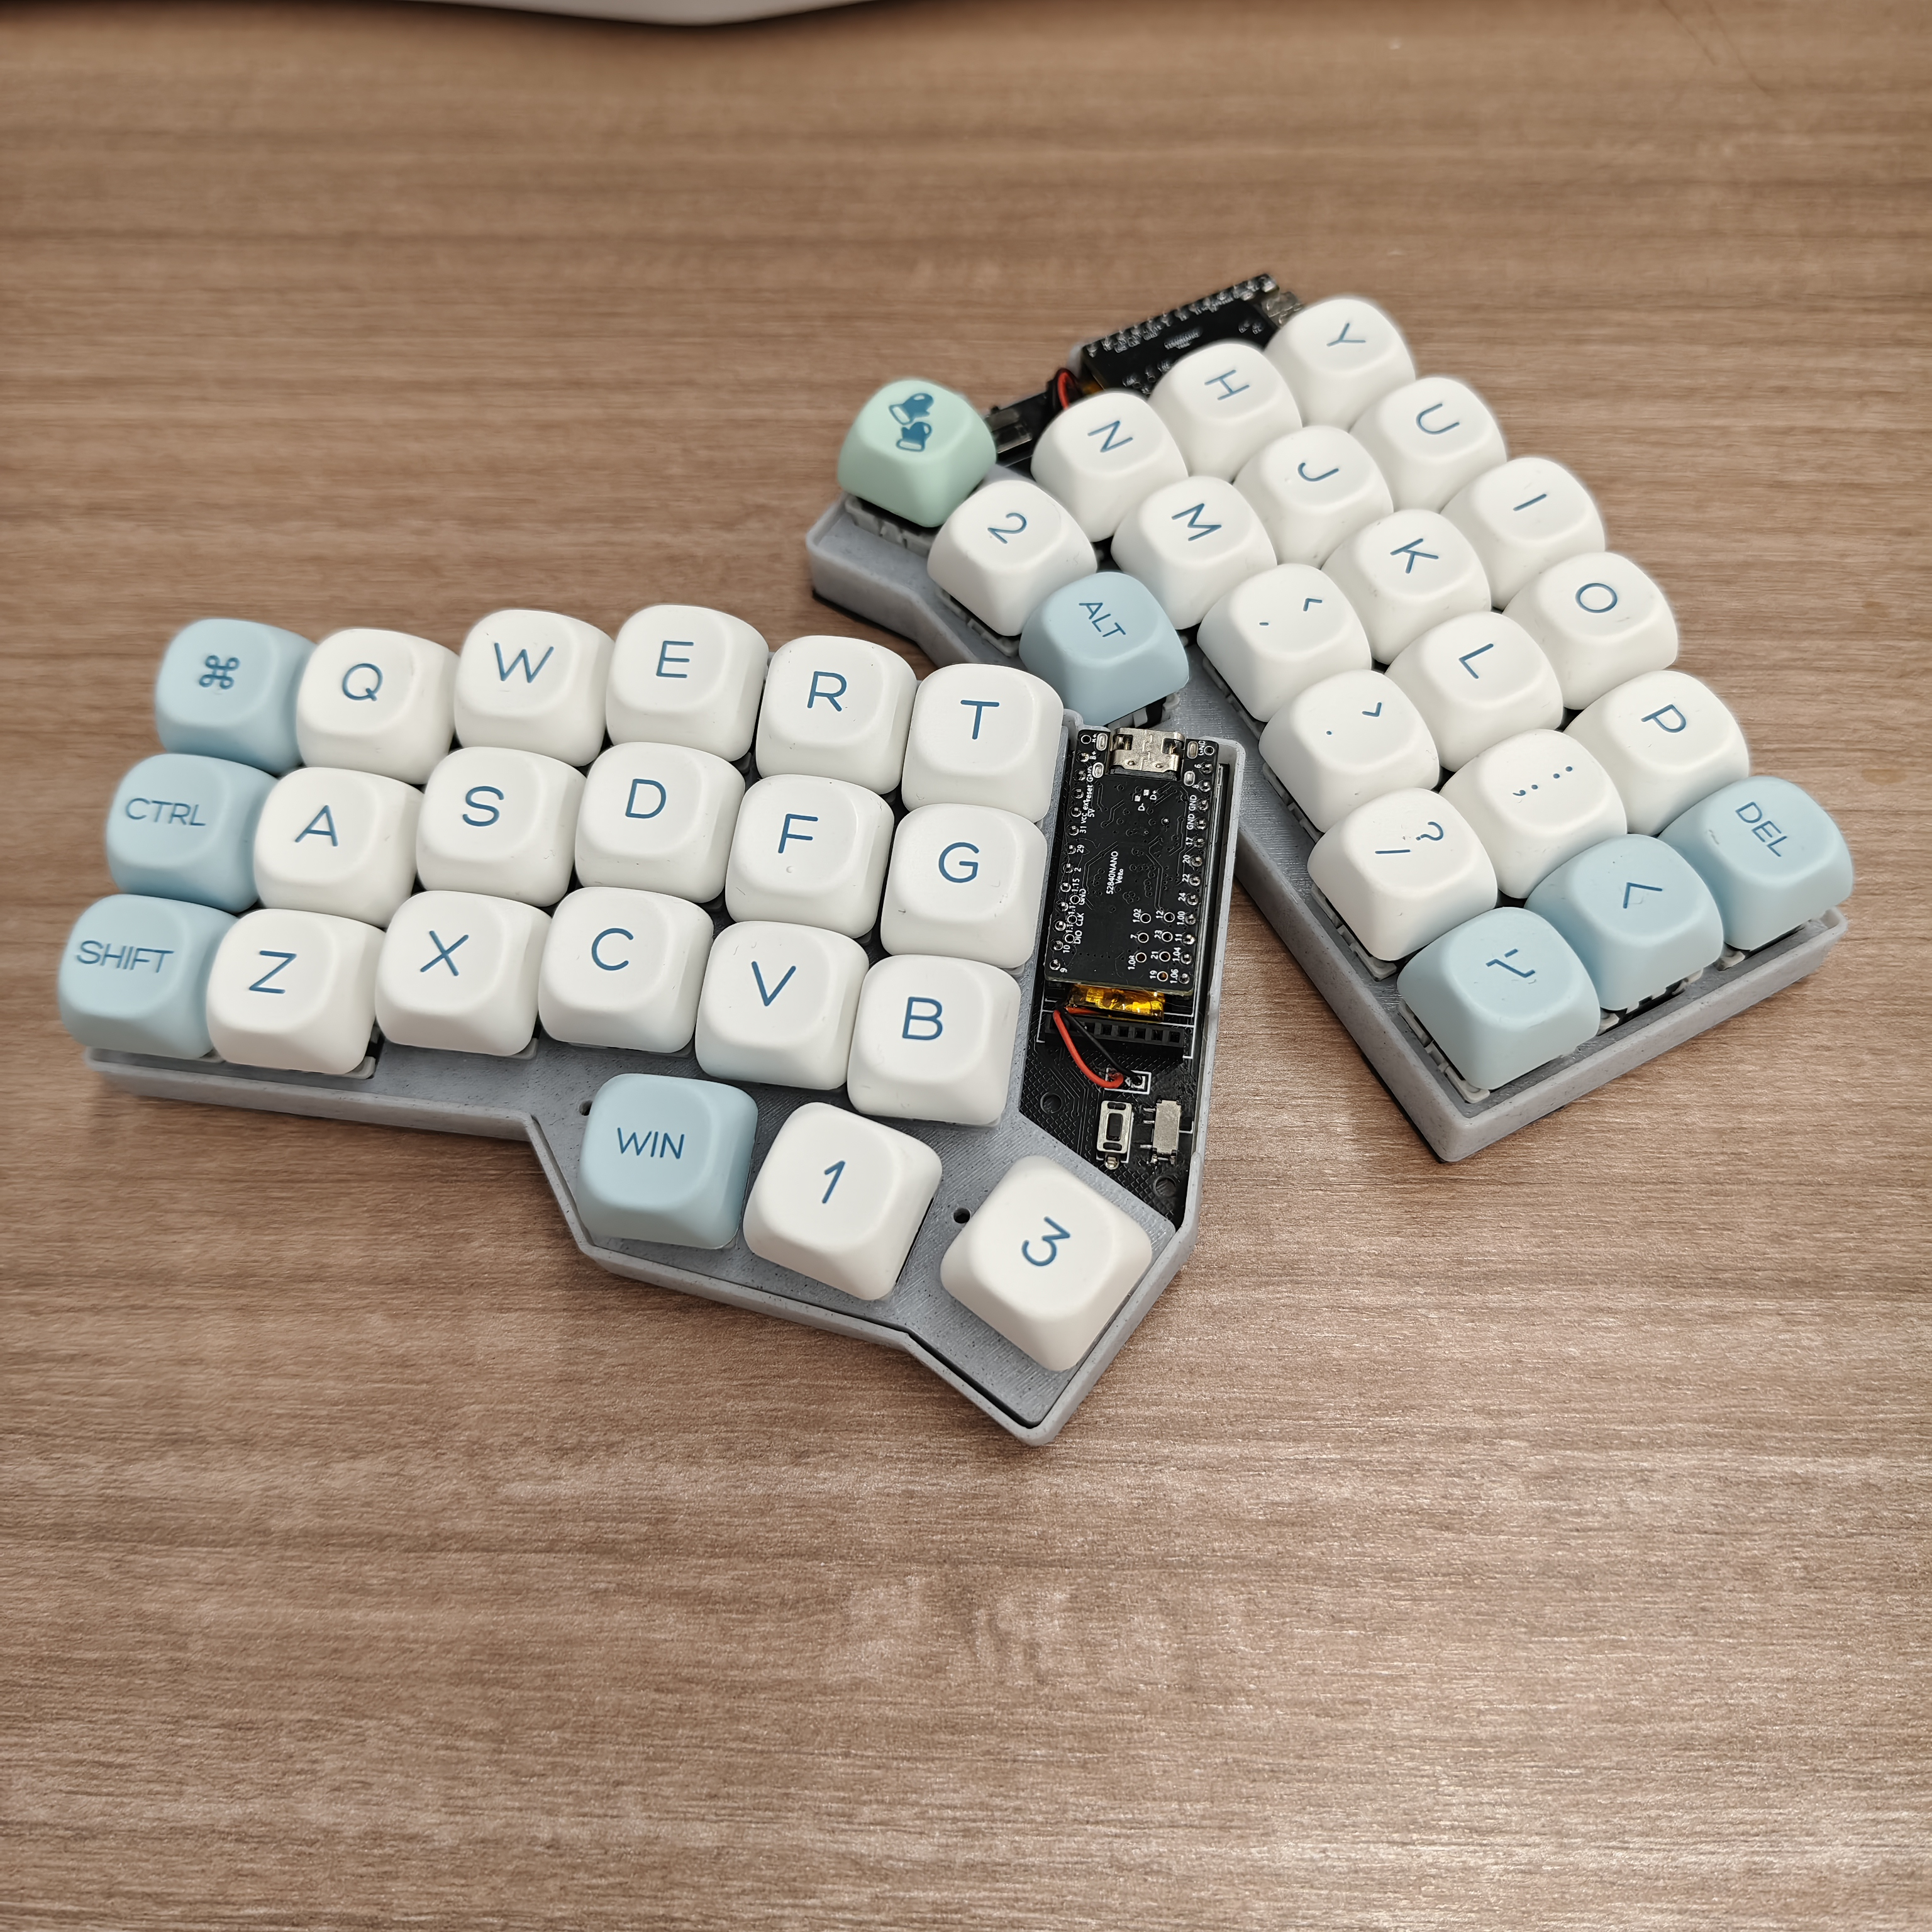
A personal keyboard build based on the open-source Corne design.
original project ↗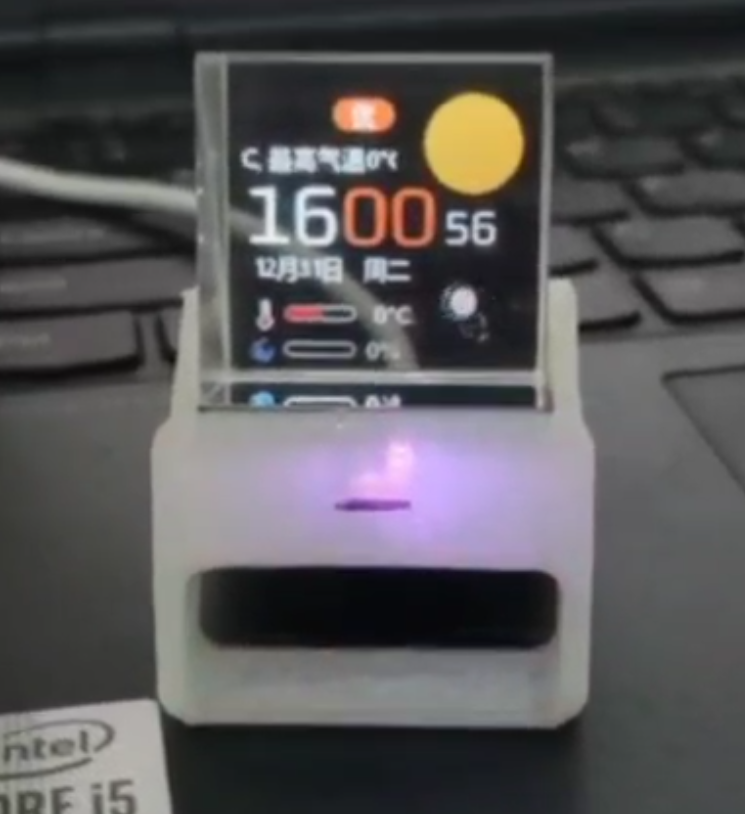
A transparent desktop display and one of my first college hardware builds.
original project ↗